EAST: Environment Aware Safe Tracking using Planning and Control Co-Design


Zhichao Li
Yinzhuang Yi
Zhuolin Niu
Nikolay Atanasov
University of California, San Diego
Accepted, 2025 Autonoumous Robots


EAST evaluates risk of collision based on robot states, moving obstacle and local environment, generates path with customizable clearance and drives the robot safely towards the goal.


This paper considers the problem of autonomous robot navigation in unknown environments with moving obstacles. We propose a new method that systematically puts planning, motion prediction and safety metric design together to achieve environmental adaptive and safe navigation. This algorithm balances optimality in travel distance and safety with respect to passing clearance. Robot adapts progress speed adaptively according to the sensed environment, being fast in wide open areas and slow down in narrow passages and taking necessary maneuvers to avoid dangerous incoming obstacles. In our method, directional distance measure, conic-shape motion prediction and custom costmap are integrated properly to evaluate system risk accurately with respect to local geometry of surrounding environments. Using such risk estimation, reference governor technique and control barrier function are worked together to enable adaptive and safe path tracking in dynamical environments. We validate our algorithm extensively both in simulation, large-scale indoor environments and challenging real-world environments with moving obstacles.


Paper

Zhichao Li, Yinzhuang Yi, Zhuolin Niu, Nikolay Atanasov

EAST: Environment Aware Safe Tracking using Planning and Control Co-Design

To be submitted to IJRR.

[arXiv (2023)]     [arXiv (final version)]    

Latest Results for IJRR


Jackal UGV navigates in an unknown large-scale cluttered working space (video playing at 2x speed).
During this experiment, goal position (green dot) is updated occassionaly by remote operator using RViz.
 

Jackal UGV navigates around static and moving obstacles (human actors wearing helmets with vicon marker).
Actors are instructed to intentionally block the way vehicle, but not being adversial in long-time horizon.
 

Algorithm comparision: Ours EAST Reference governor-based (left) vs. EVA Planner (Quan. Lun, et al. 2021) MPC-based (right)
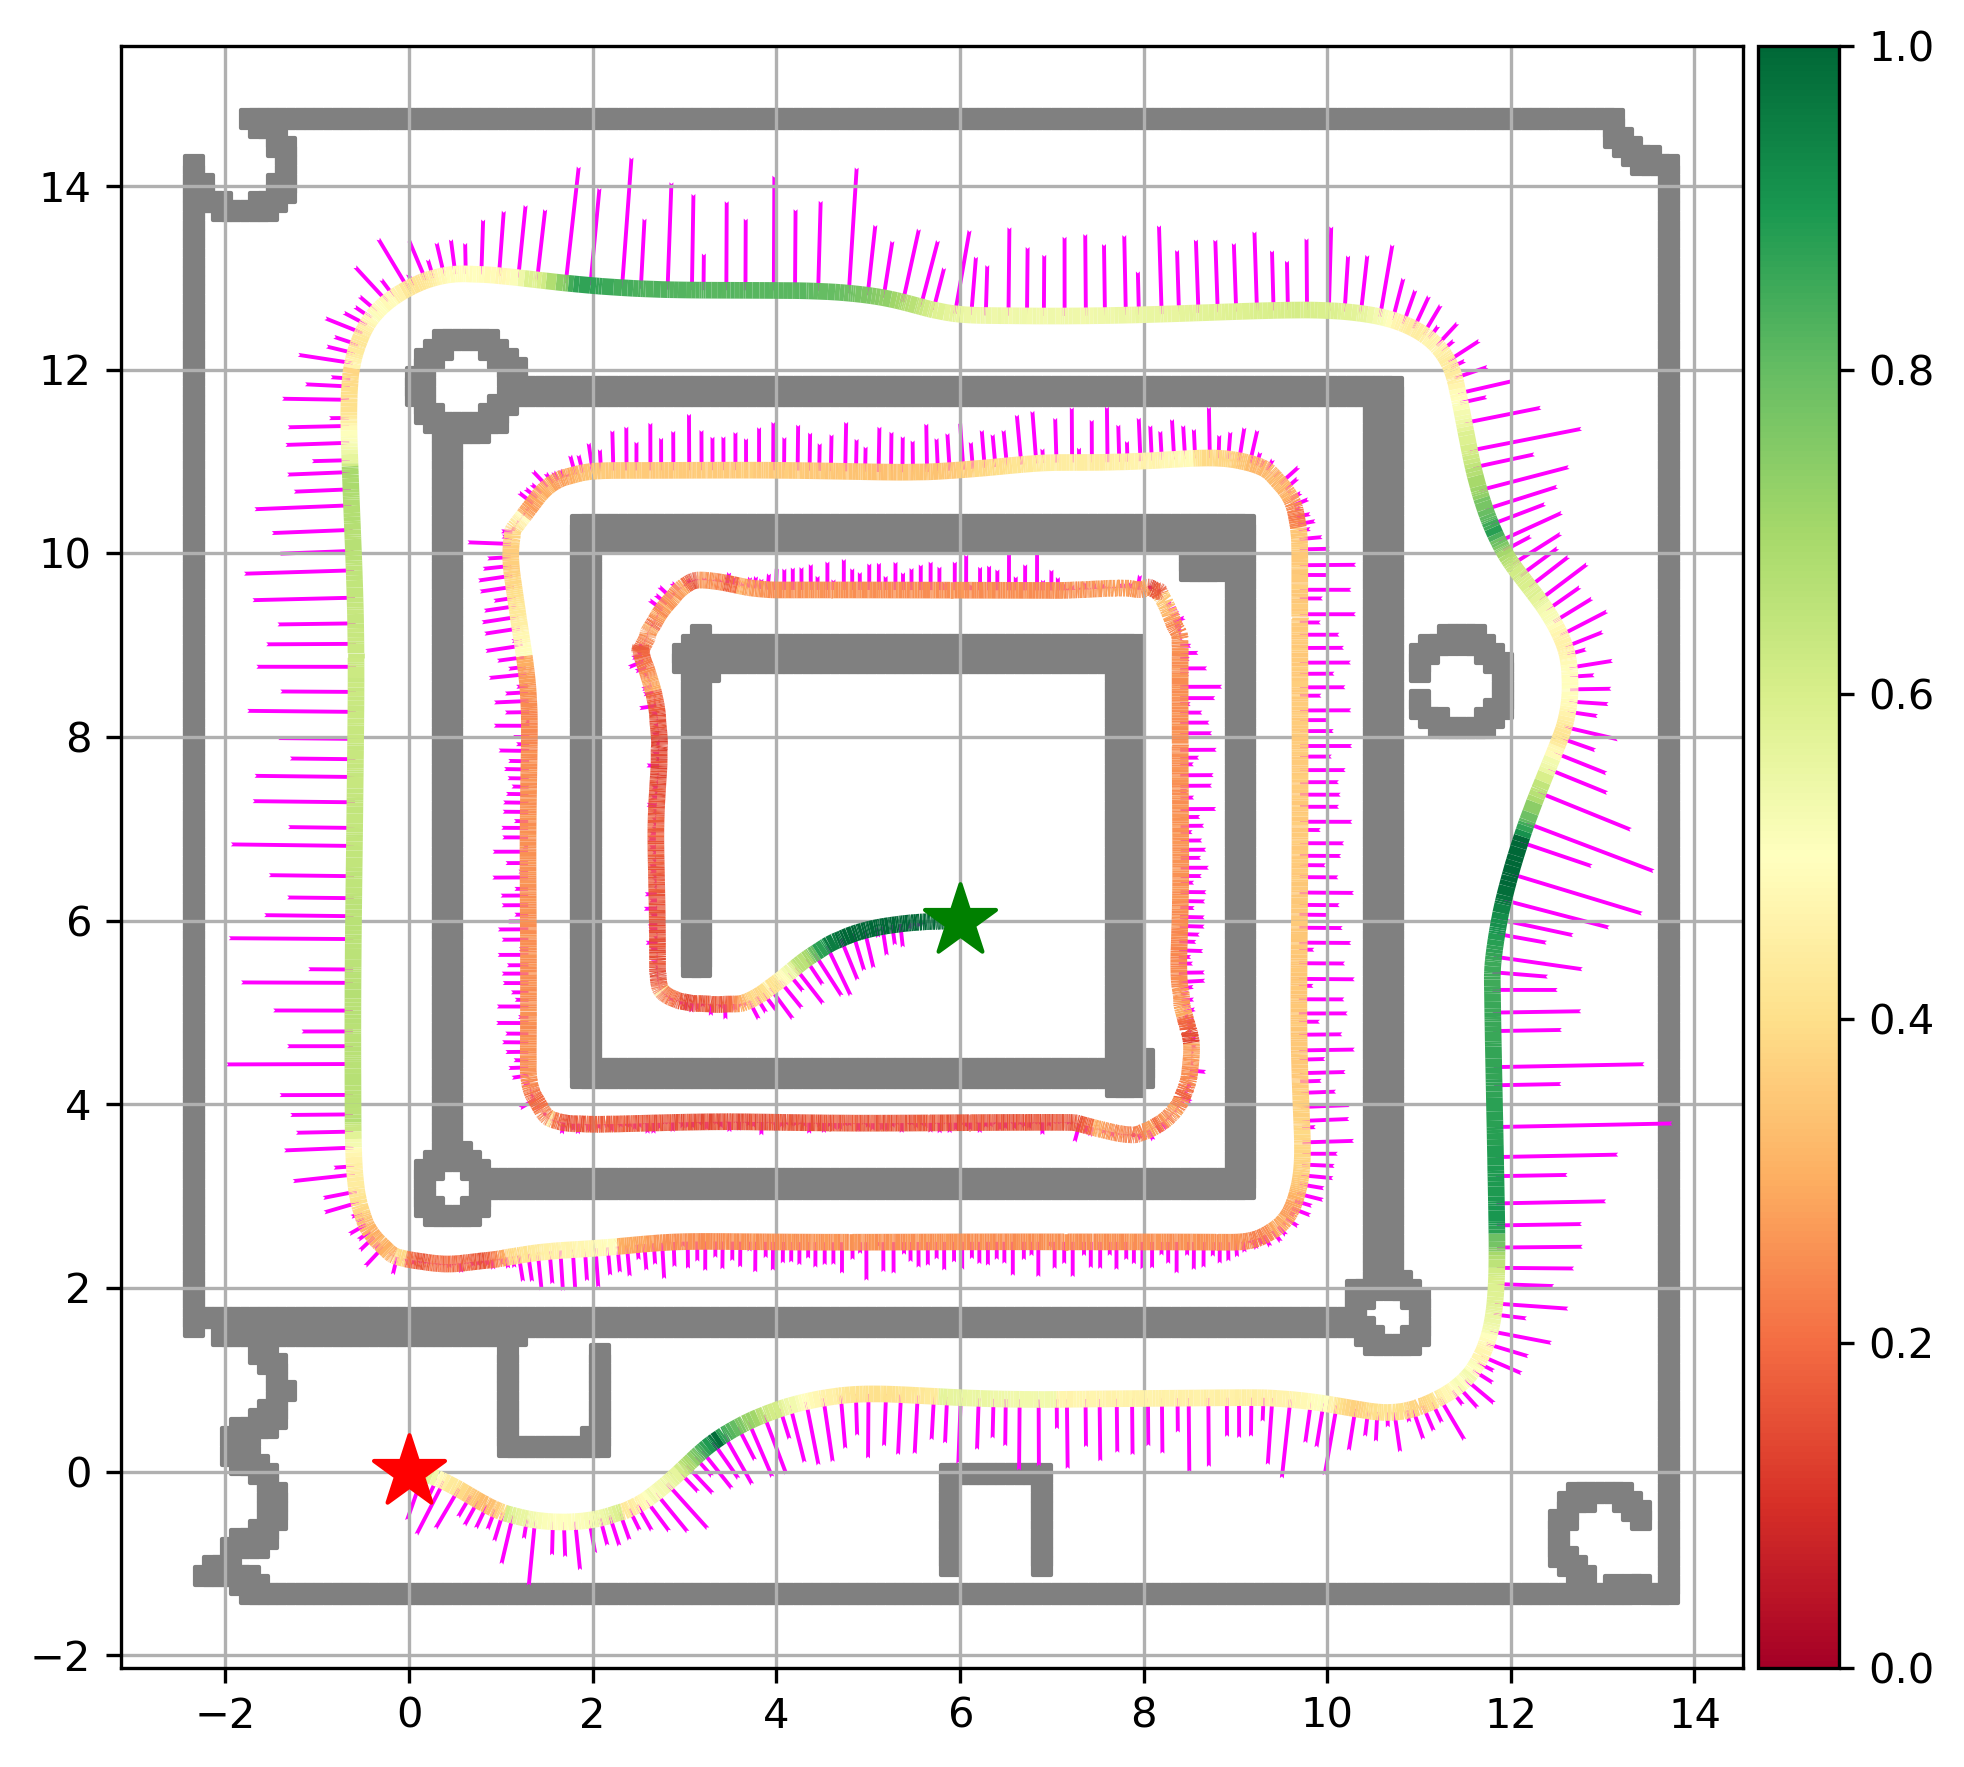
Adaptivity test in uknown maze in which corridors getting narrower from outer to inner region. Jackal UGV needs to go through it without collision. The start and the goal are denoted by a red and green star, respectively. The colored curve represents the actual robot trajectory with the robot to the inflated obstacle space shown by gradient color corresponding to the side color bar. The tracking velocity profiles are shown as magenta arrows perpendicular to the robot trajectories.


Overview and Results


Code


 [Available in Nov. 2023]


Acknowledgements

This webpage template was borrowed from https://thaipduong.github.io/kernelbasedmap/.